

Architect of Software Intelligence & Physical Actuation · Founder @ MECH


I bridge the chasm between pure software reasoning and physical robotics actuation.
Most AI systems remain trapped behind browser windows and cloud APIs. My work connects high-order cognitive models directly into motors, cameras, custom PCBs, and mechanical frames. Day to day: fine-tuning LLMs on 1M+ conversation pairs, designing custom circuits in KiCad, building real-time computer vision pipelines, and engineering embedded firmware for autonomous systems.
As founder of MECH, every software utility, companion runtime, and hardware prototype feeds into a single long-term horizon: embodied intelligence that inhabits and impacts physical reality.
- 💠 Flagship Focus: Mio (Embodied Companion AI) · Reception (B2B Enterprise AI) · KiCad MCP
- 💠 Hardware Track: Custom ESP32 PCBs · Wearable Smart Goggles · ROS2 Actuation
- 💠 The Crucible: 46 Hackathons fought under extreme constraints · 14 National & International Wins
An animated trajectory from zero knowledge to autonomous systems — narrated by the Shorekeeper butterfly.
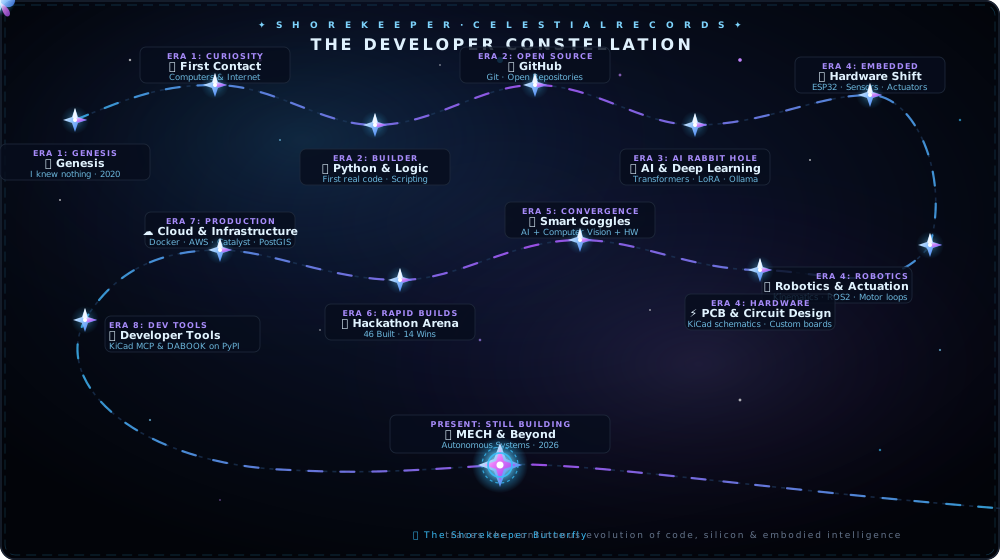
🌌 Expand the 8 Eras of the Trajectory
| Era | Milestone | Technical Epoch | Key Breakthrough |
|---|---|---|---|
| 🌱 01 | Genesis | “I knew basically nothing” · First computer contact & internet curiosity | Discovery of how software works |
| 💻 02 | The Builder | Python syntax → scripts, web parsers, automation & Git repositories | Moving from passive learner to active creator |
| 🧠 03 | AI Rabbit Hole | NLP, PyTorch, Transformers, Hugging Face, fine-tuning, RAG & Ollama | Training Mio on 1M+ datasets · local inference |
| 🔌 04 | Hardware Shift | “Software wasn’t enough” · ESP32, sensors, actuators, Fusion 360, KiCad PCBs | Routing circuits & understanding physical silicon |
| 👓 05 | The Convergence | AI + Computer Vision + Embedded hardware collide | Building wearable Smart Goggles & pose systems |
| 🏆 06 | The Crucible | 46 Hackathons tackled under ruthless deadlines · 14 Wins | Shipping Sentinel (Karnataka Police), PosChair, IgniteGap |
| ☁️ 07 | Production & Scale | Docker, AWS, GCP, Azure, Zoho Catalyst (AppSail), PostGIS, Supabase | Deploying resilient, million-row geo-spatial platforms |
| 📦 08 | Developer Tooling | Building tools for others: KiCad MCP Server & DABOOK on PyPI | Extending AI agent capabilities into electronics design |
| 🌌 Present | MECH & Beyond | Autonomous embodied systems · Code → Silicon → Actuation | Still building... The butterfly continues onward. |
Local Edge Deployment: Ollama · LLaMA · Qwen 2.5 · Mistral · Zephyr · GPT-2 · AutoTokenizer · compressed embeddings · local model serving


An AI & Robotics enterprise. Intelligence is not just software running on a server;
it is the brain that breathes life into physical machines.
Software & Runtime Products
| System | Classification | Architectural Purpose | Status |
|---|---|---|---|
| Mio | Embodied Companion | Conversational reasoning engine fine-tuned on 1M+ conversation pairs with persistent long-term memory & local edge inference. Zero cloud reliance. | Active |
| Reception | Enterprise AI SaaS | AI receptionist platform managing guest check-ins, automated scheduling, and natural spoken dialogue for corporate spaces. | Active |
| KiCad MCP | AI CAD Infrastructure | Model Context Protocol server enabling LLM agents to inspect, manipulate, and generate circuit schematics and PCB designs via dynamic protobufs. | Active |
| AetherXD | Desktop Agent Runtime | Local agent orchestrator and OS automation shell running directly on user hardware. | Active |
| DABOOK | Developer Tool | Published Python package on PyPI streamlining developer workflow automation and packaging. | Shipped |
| DocaMech | System Utility | Automated file classifier and organizer operating locally as a licensed desktop application. | Prototype |
Hardware Roadmap
| System | Hardware Subsystem | Horizon |
|---|---|---|
| Robot Arm | AI-driven 6-DoF mechanical manipulator with computer vision feedback and ROS2 kinematic solver | Future |
| Smart Goggles | Wearable heads-up display combining ESP32, micro-camera, MediaPipe CV, and ambient HUD | Prototyping |
| PosChair | Ergonomic intelligent chair utilizing distributed pressure sensors and haptic posture feedback | Prototype |
| MECH Core IoT | Unified embedded home automation firmware: Tank level telemetry, motor control, leak sensing | Planned |
| Workspace Rails | Overhead rail-guided actuator for automated laboratory tool transport and spatial positioning | Concept |

Full-stack crime pattern analysis and geospatial intelligence suite engineered for the Karnataka State Police during the H2S Datathon.
- Features spatial clustering, police jurisdiction boundary mapping, interactive crime heatmaps, and an integrated AI analysis assistant.
- Tech Stack: FastAPI · React · PostGIS · PostgreSQL · Docker · KML / Shapefiles
- → Explore Sentinel Repository
Conversational agent fine-tuned on a custom curated corpus of over 1,000,000 conversation pairs.
- Engineered specifically for local edge inference without cloud telemetry, persistent conversational memory, and future integration into physical robotic bodies.
- Tech Stack: PyTorch · PEFT / LoRA · Ollama · Transformers · SFTTrainer · Local Quantization
- → Explore MECH Core R&D
Model Context Protocol server connecting AI assistants directly into KiCad EDA.
- Implements dynamic Protocol Buffer (protobuf) descriptors, dynamic tool injection, and schema reflection, allowing LLM agents to audit circuits and route boards autonomously.
- Tech Stack: Python · KiCad · Model Context Protocol · Protobuf · AI Tooling
- → Explore Hardware & AI Stack
Official Python package published to the Python Package Index (PyPI) providing developer productivity utilities, batch processing, and pipeline automation.
- Designed for modular integration into data preprocessing workflows.
- Tech Stack: Python · PyPI · Packaging · CLI · Automation
- → View DABOOK on PyPI
Physical wearable and IoT hardware prototypes combining real-time computer vision, low-power embedded microcontrollers, and lightweight optics.
- Smart Goggles: ESP32-C3 · OpenCV · MediaPipe · OLED Display · 3D Printed Chassis
- PosChair: IoT smart chair equipped with embedded tactile pressure arrays that continuously classify seating posture and provide proactive ergonomic corrections.


"46 hackathons taught me one indelible truth: ideas are cheap; executing an end-to-end working system from scratch in 36 hours is the ultimate crucible."
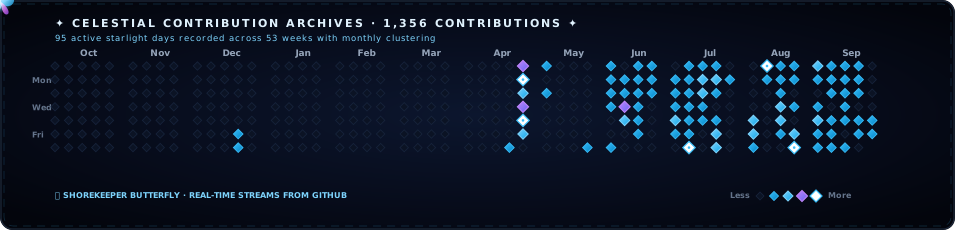
Open to ambitious builders who operate with conviction and technical rigor.
| Role | Preferred Collaboration Vectors |
|---|---|
| Researchers | Local LLM compression, quantization, edge embodied AI, agentic state coordination |
| Engineers | Embedded firmware, custom PCB layout, ROS2 kinematics, desktop systems |
| Founders | Technical co-building, system architecture, bridging AI into hardware |
| Hackathon Teams | Fast-paced, high-stakes full-stack and hardware engineering |

“Like butterflies navigating the cosmos, code leaves an enduring constellation.”
GitHub · LinkedIn · X (Twitter) · PyPI
Crafted in Shorekeeper Starlight · © 2026 Vaibhav Kumar & MECH